十字轴万向联轴器
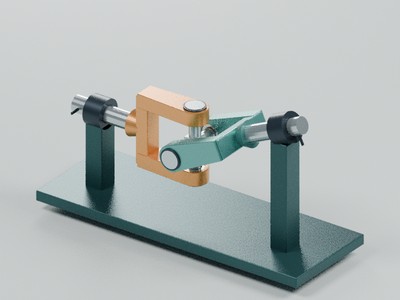
十字轴万向联轴器:两根相交轴通过两只叉与正交十字轴传递转动。
What is it made of?
01 双轴支架
两轴线在十字轴中心相交,夹角 25°。
02 输入轴与叉
橙色输入叉绕水平主轴旋转,圆头叉耳内有真实轴承杯孔,与十字轴的一对耳轴相接。
03 输出轴与叉
绿色输出叉绕倾斜主轴旋转,其角速度并非恒定。
04 输入叉轴承杯与挡圈
两只闭底杯装入叉耳孔;内衬支承十字轴颈,外挡圈限制杯轴向外移。
05 输出叉轴承杯与挡圈
轴承杯围绕另一对正交轴颈;本代表版本采用滑动衬套,不声称滚针轴承。
06 正交十字轴
两根轴互相垂直;一对随输入叉,另一对随输出叉。
07 主轴轴承座
简化的固定轴承座,不随轴旋转。
How do the parts work together?
叉耳轴与各自主轴垂直,十字轴的两根耳轴始终正交;输入匀速时输出呈周期速度波动。
工作运动:输入叉、正交十字轴和输出叉真实联动;25° 夹角产生周期性输出速度波动。
Model scope and approximations
AI-assisted educational schematic, not manufacturing CAD. Materials, proportions and movements are limited to this model's description.
固定轴夹角25°;采用滑动衬套式十字轴代表版本,轴承杯/衬套/挡圈均独立几何;省略润滑油道及密封;不含载荷或强度计算。
Sources
- Primary academic mechanism reference
CMU §8.5 specifies two forks pin-jointed to a right-angle cross, intersecting angled shafts, and a nonconstant instantaneous velocity ratio between cos(beta) and 1/cos(beta). Model constructs orthogonal trunnion vectors exactly; angle convention has a quarter-turn phase offset.
- Ruland universal joints
厂家列明single universal joints、friction bearing和yoke/trunnion组成;本模型选择滑动衬套式,不宣称滚针结构。